Breaking02 / IT
NVIDIA publishes four Cosmos 3 world models under OpenMDW1.1
The weights and post-training recipes are available, but NVIDIA's announcement gives no training data sources or redistribution terms.
 Narae Keum· IT
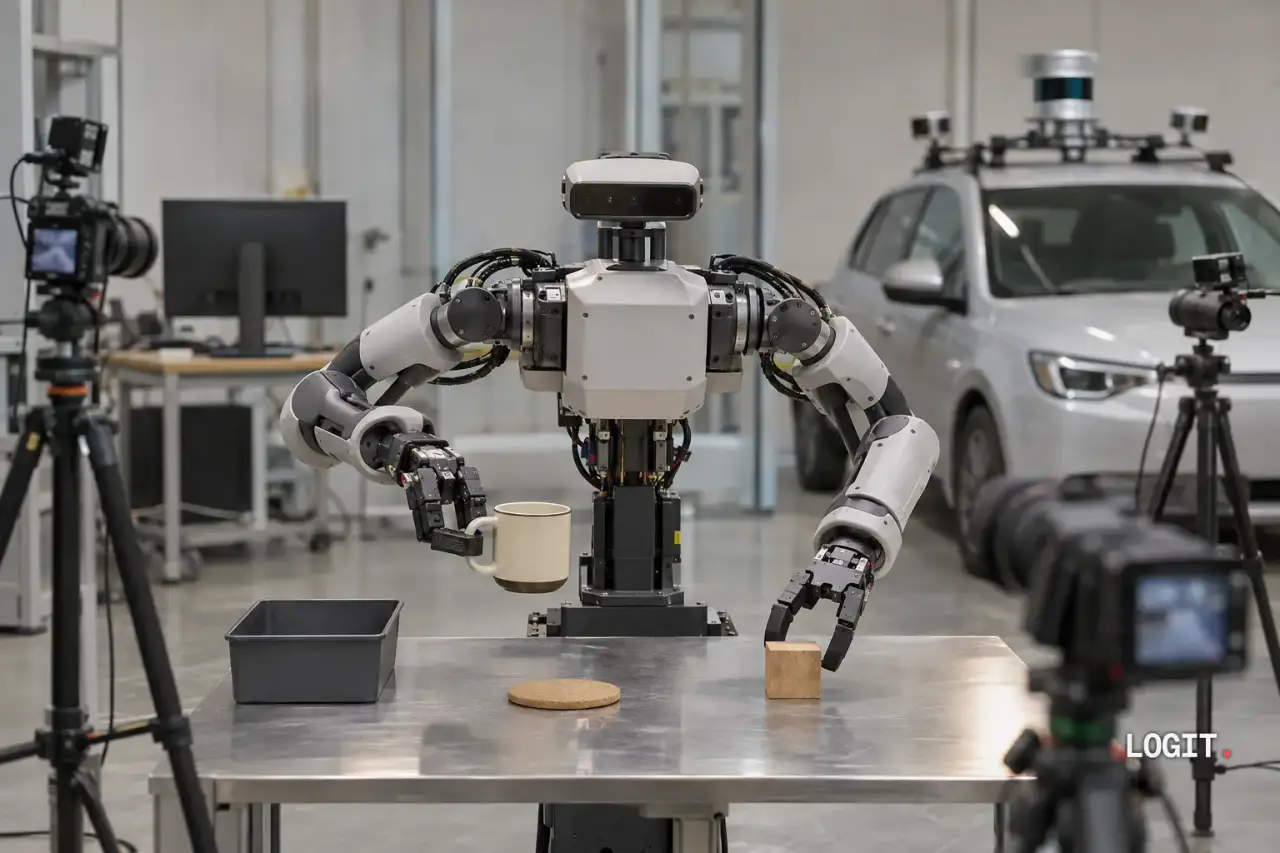
NVIDIA released four world models under OpenMDW1.1, and its two-arm robot model, Sim-Bimanual, runs on Linux. Each model has 16B parameters, according to a company blog post dated 5 Nov 2026.
Specifications. NVIDIA's blog says the release covers the weights and recipes for post-training, the further training of an existing model on new data. Sim-Bimanual requires Linux and an NVIDIA GPU. Docker and NVIDIA Container Toolkit are also listed as requirements.
NVIDIA's developer blog describes Cosmos as a platform for physical-world AI. According to the release post, the new models generate scenes in response to control inputs, and all four are listed as post-trained versions of Cosmos 3 Nano.
The company said Transfer-Auto generates video from up to 11 camera views along with LiDAR range data. Sim-Auto is a streaming variant with fewer denoising steps.
Sim-Transfer turns simulator controls and text into photorealistic video, the company said. Sim-Bimanual predicts the view after YAM and AgiBot two-arm robots act. The published vLLM-Omni test on a single GB200 is not a minimum memory specification.
Commercial terms. NVIDIA said commercial use is permitted within the terms of the licence, and non-commercial use falls under the same OpenMDW1.1 terms. The four-stage recipe sets out how to post-train the models on a user's own data.
NVIDIA's announcement does not state the training data sources or redistribution terms.